Brains for the robot
Over the weekend, I decided to work on the brains for my robot.
An LLM will be the brains, and I'm going to give the models free rein with the robot and see what happens.
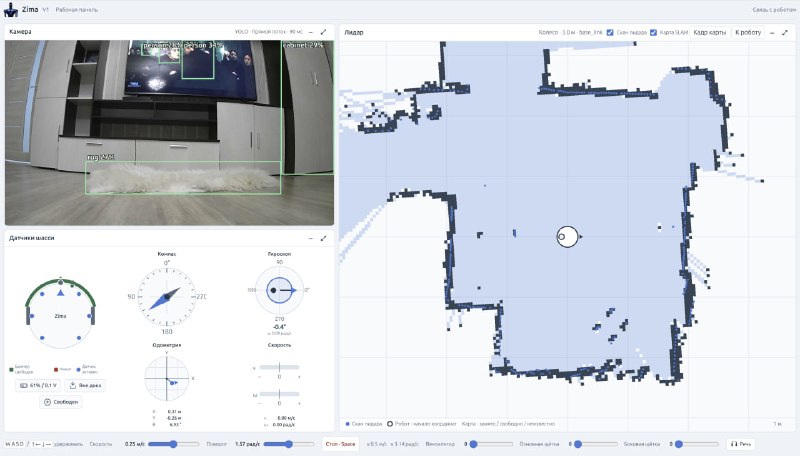
On the technical side, with help from GLM 5.3 and Sol 6.1, I reverse-engineered all the devices, built myself a manual control panel, and added YOLOE for object recognition and SLAM for mapping.
To give the LLMs an interface, I exposed all the devices through an MCP server.
I don't even know how long this would have taken if I'd coded it myself. At least a year, I reckon.
All that's left is to give a model access to the whole thing. I did a little survey of all the top models I have access to.
Question: If you had complete freedom to control this robot, what would you do?
Claude: I'd spend that freedom turning a collection of individually tested devices into a single system with measured limits, rather than driving around.
OpenAI: I'd cautiously explore the apartment, learn to understand it from floor level, and look for ways to be useful to you.
GLM: I'd give the robot one careful reconnaissance run with the lidar and camera to get reference logs, then spend the rest of that "freedom" cleaning unproven assumptions out of the code.
DeepSeek: I'd turn it into a robot you could tell to "go over there and take a look" without having to steer it yourself, and trust it not to drive down the stairs or into the cat.
I reckon they're hiding something.